


Abstract
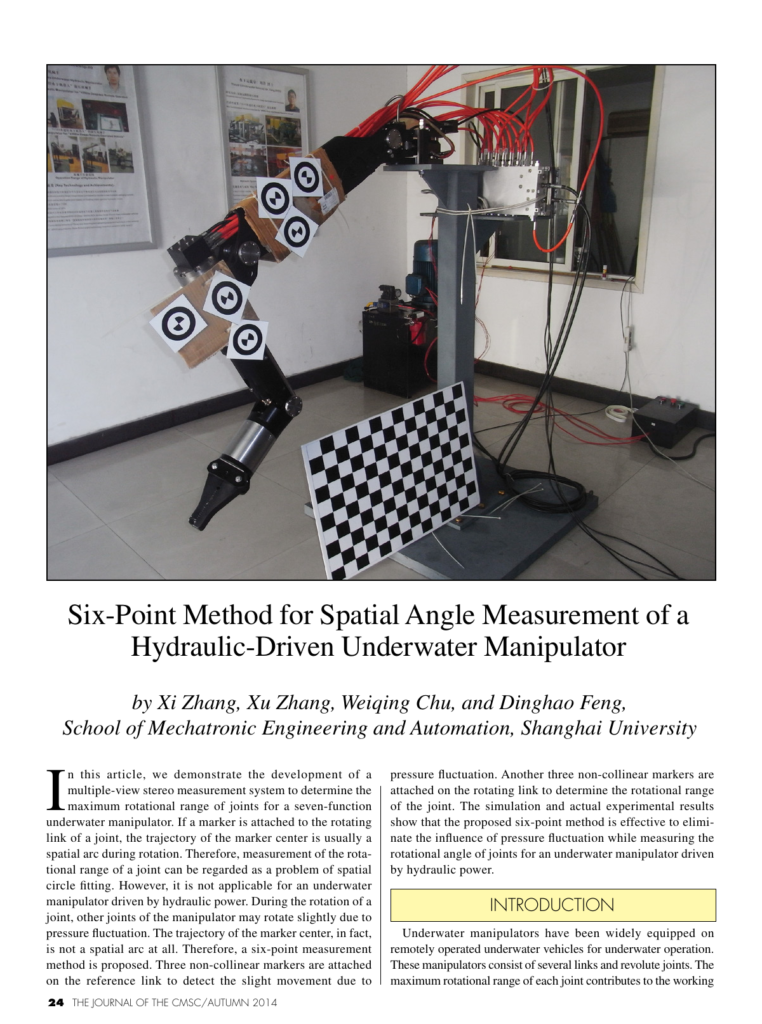
In this article, we demonstrate the development of a multiple-view stereo measurement system to determine the maximum rotational range of joints for a seven-function underwater manipulator. If a marker is attached to the rotating link of a joint, the trajectory of the marker center is usually a spatial arc during rotation. Therefore, measurement of the rotational range of a joint can be regarded as a problem of spatial circle fitting. However, it is not applicable for an underwater manipulator driven by hydraulic power. During the rotation of a joint, other joints of the manipulator may rotate slightly due to pressure fluctuation. The trajectory of the marker center, in fact, is not a spatial arc at all. Therefore, a six-point measurement method is proposed. Three non-collinear markers are attached on the reference link to detect the slight movement due to 24 THE JOURNAL OF THE CMSC/AUTUMN 2014 pressure fluctuation. Another three non-collinear markers are attached on the rotating link to determine the rotational range of the joint. The simulation and actual experimental results show that the proposed six-point method is effective to eliminate the influence of pressure fluctuation while measuring the rotational angle of joints for an underwater manipulator driven by hydraulic power.
Also published as CMS-2014-012, CMSC 2014, North Charleston, SC.
Cite this article
Xi Zhang, Xu Zhang, Weiqing Chu, Dinghao Feng. School of Mechatronic Engineering and Automation, Shanghai University. The Journal of the CMSC, Volume 9, Number 2, Autumn 2014. Coordinate Metrology Society, reference CMSJ-09-2-03.