


Abstract
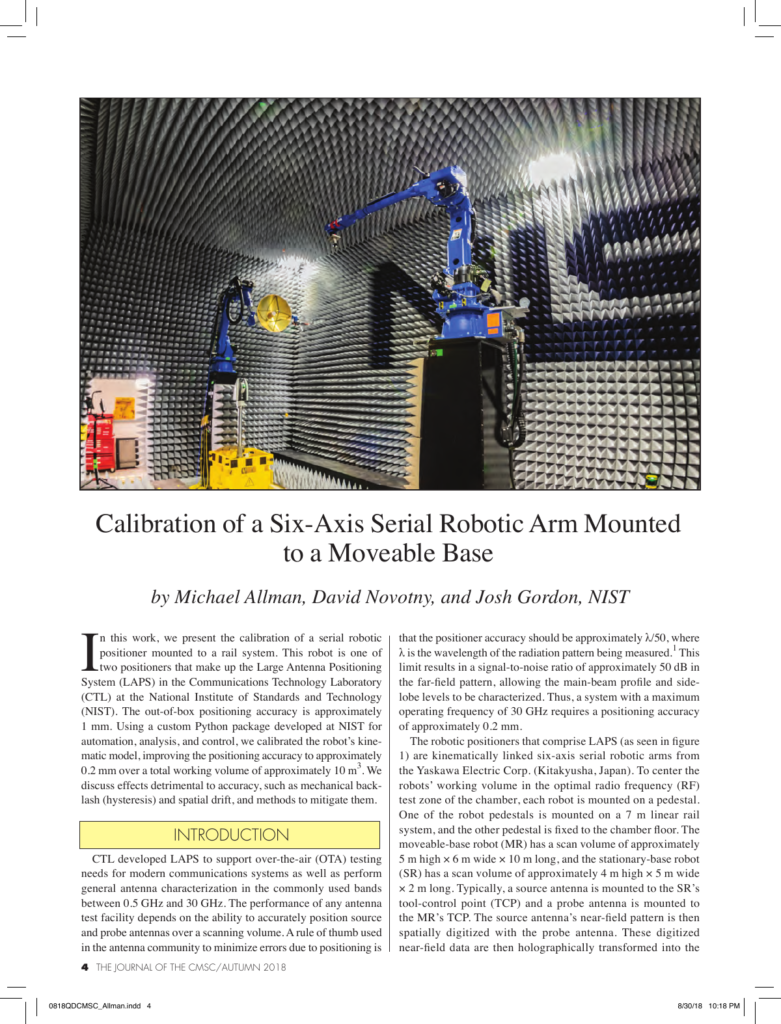
In this work, we present the calibration of a serial robotic positioner mounted to a rail system. This robot is one of two positioners that make up the Large Antenna Positioning System (LAPS) in the Communications Technology Laboratory (CTL) at the National Institute of Standards and Technology (NIST). The out-of-box positioning accuracy is approximately 1 mm. Using a custom Python package developed at NIST for automation, analysis, and control, we calibrated the robot’s kinematic model, improving the positioning accuracy to approximately 0.2 mm over a total working volume of approximately 10 m3. We discuss effects detrimental to accuracy, such as mechanical backlash (hysteresis) and spatial drift, and methods to mitigate them. INTRODUCTION CTL developed LAPS to support over-the-air (OTA) testing needs for modern communications systems as well as perform general antenna characterization in the commonly used bands between 0.5 GHz and 30 GHz. The performance of any antenna test facility depends on the ability to accurately position source and probe antennas over a scanning volume.
Also published as CMS-2018-020, CMSC 2018, Reno, NV.
Cite this article
Michael Allman, David Novotny, Josh Gordon. National Institute of Standards and Technology (NIST). The Journal of the CMSC, Volume 13, Number 2, Autumn 2018. Coordinate Metrology Society, reference CMSJ-13-2-01.